Research · CoRL 2026 · Spotlight
WireCraft
A CoRL 2026 Spotlight benchmark for training and evaluating robot policies on contact-rich, flexible-wire manipulation in simulation and on physical hardware.
What I worked on
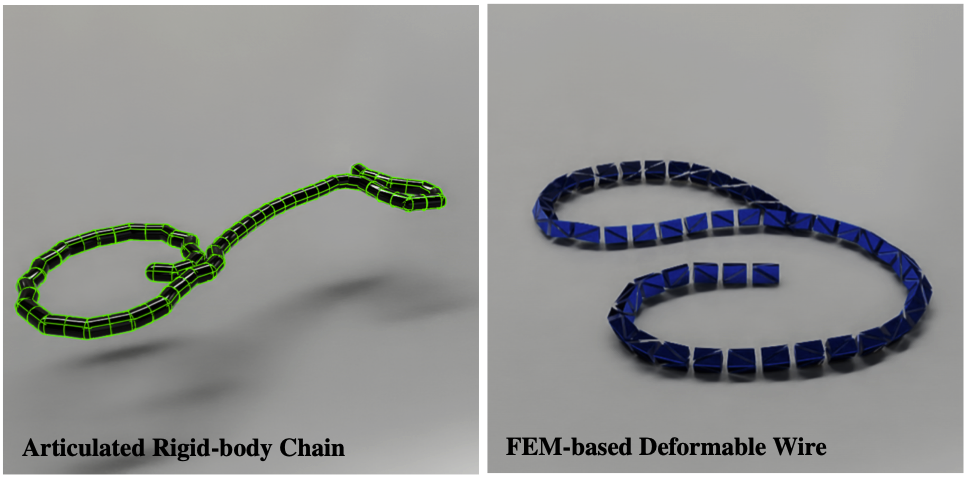
- Built and benchmarked Isaac Lab environments for articulated and deformable wires, using PPO, reward shaping, routing demonstrations, and task-success metrics to train and evaluate manipulation policies.
- Built LeRobot-compatible datasets and scalable training and inference pipelines; deployed, fine-tuned, and evaluated π0.5, ACT, and multi-task DiT policies for physical UR5 wire manipulation.
- Investigated rare, nondeterministic PhysX failures that appeared millions of RL steps into training by adding joint-state logging and a Three.js replay tool.
- Traced sharp angular-velocity spikes to unstable contact configurations, informing contact-mesh changes that made training substantially more stable.
- Showed that combining simulated and real demonstrations improved physical-robot performance over training on real demonstrations alone.